top of page
Robotic Car
Objective: Develop a fully autonomous, 3D-printed, and laser-cut robot car designed to transport a 1kg payload, log sensor data, and traverse inclines independently.
Ideation
Three initial design concepts were sketched.


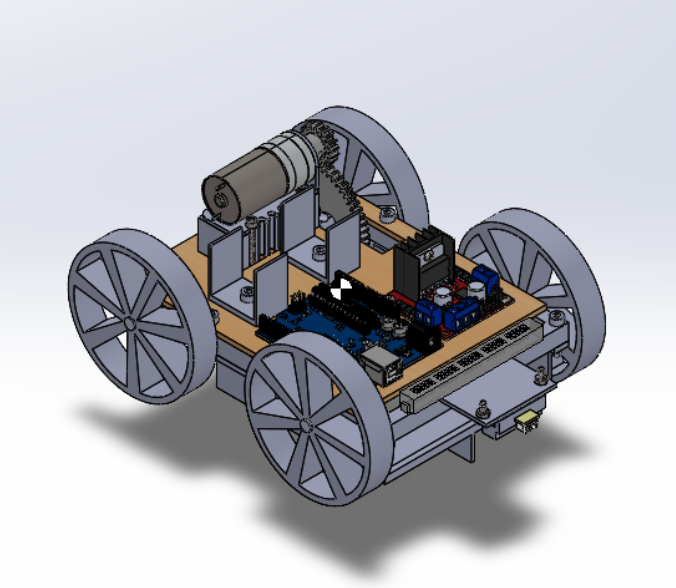
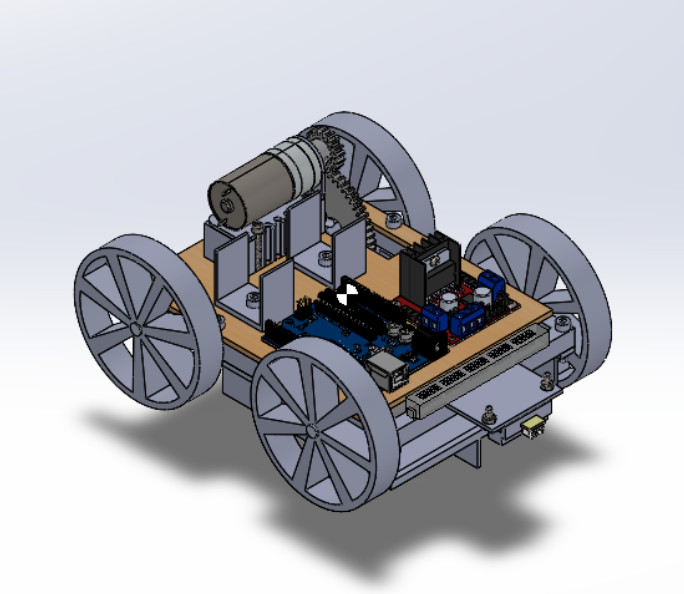
CAD Design Modeling

Calculations
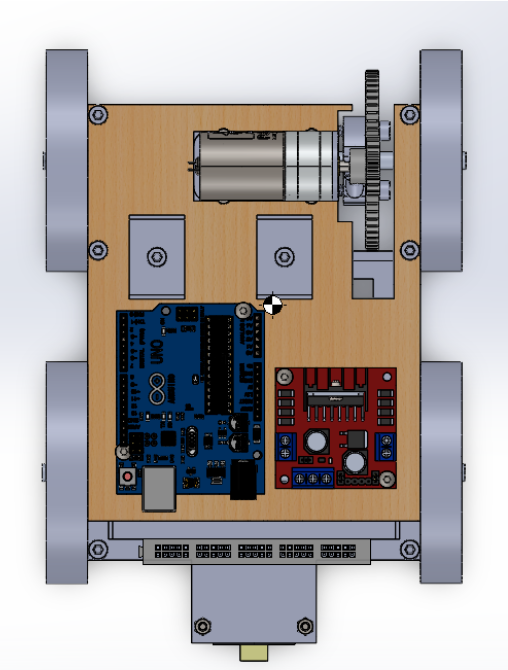
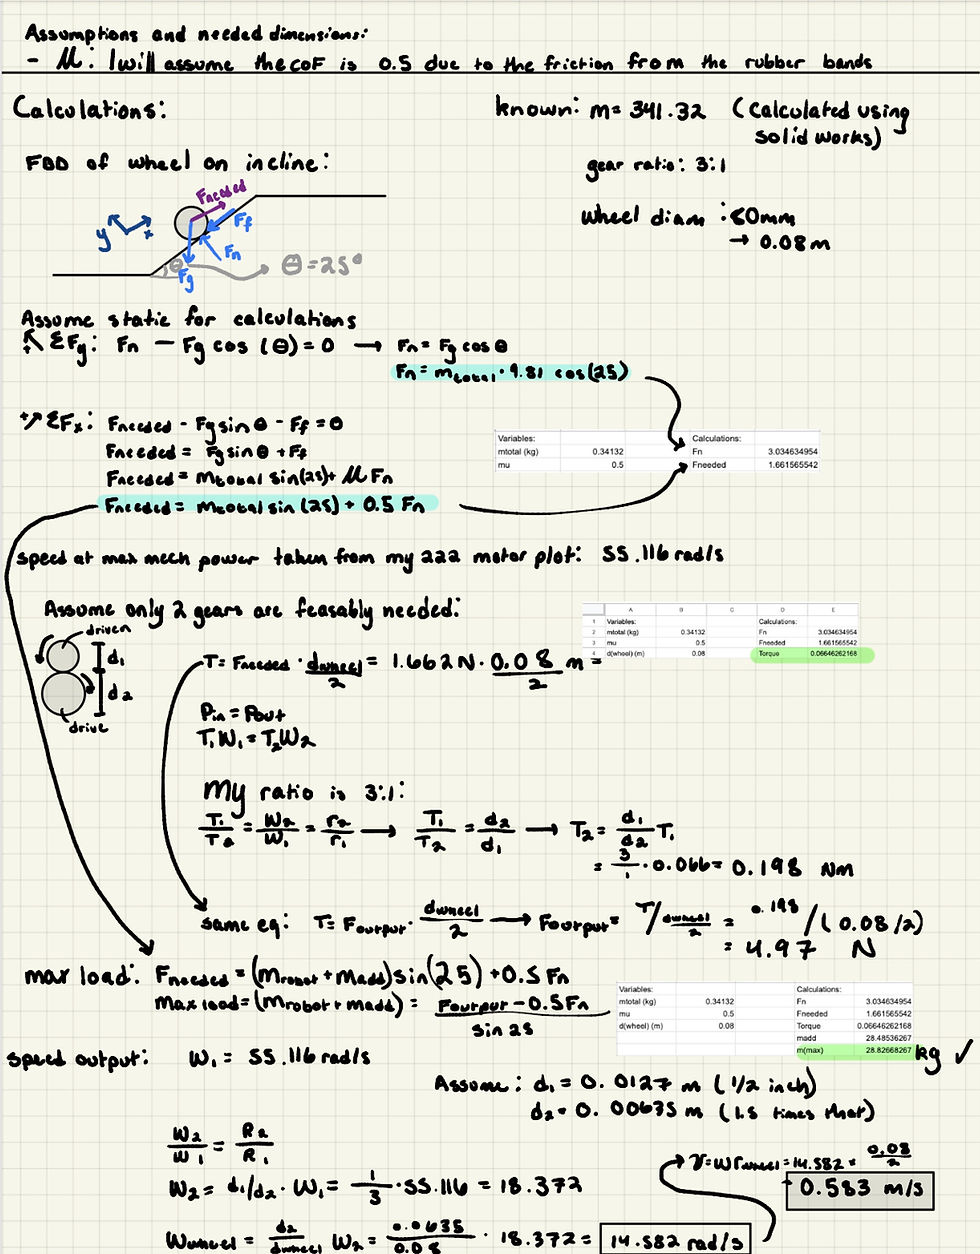
Analyses of physical dimensions, weight distribution, and component layout—including the Arduino, H-bridge, and battery—confirmed a 3:1 gear ratio. This setup optimizes the center of mass to ensure maximum stability. Precise spatial planning for the motors and breadboard was essential to achieving this low, centered gravitational profile.
Finished Vehicle

bottom of page